
Energy-efficient robotic inspection in under-panel spaces of photovoltaic plants
-
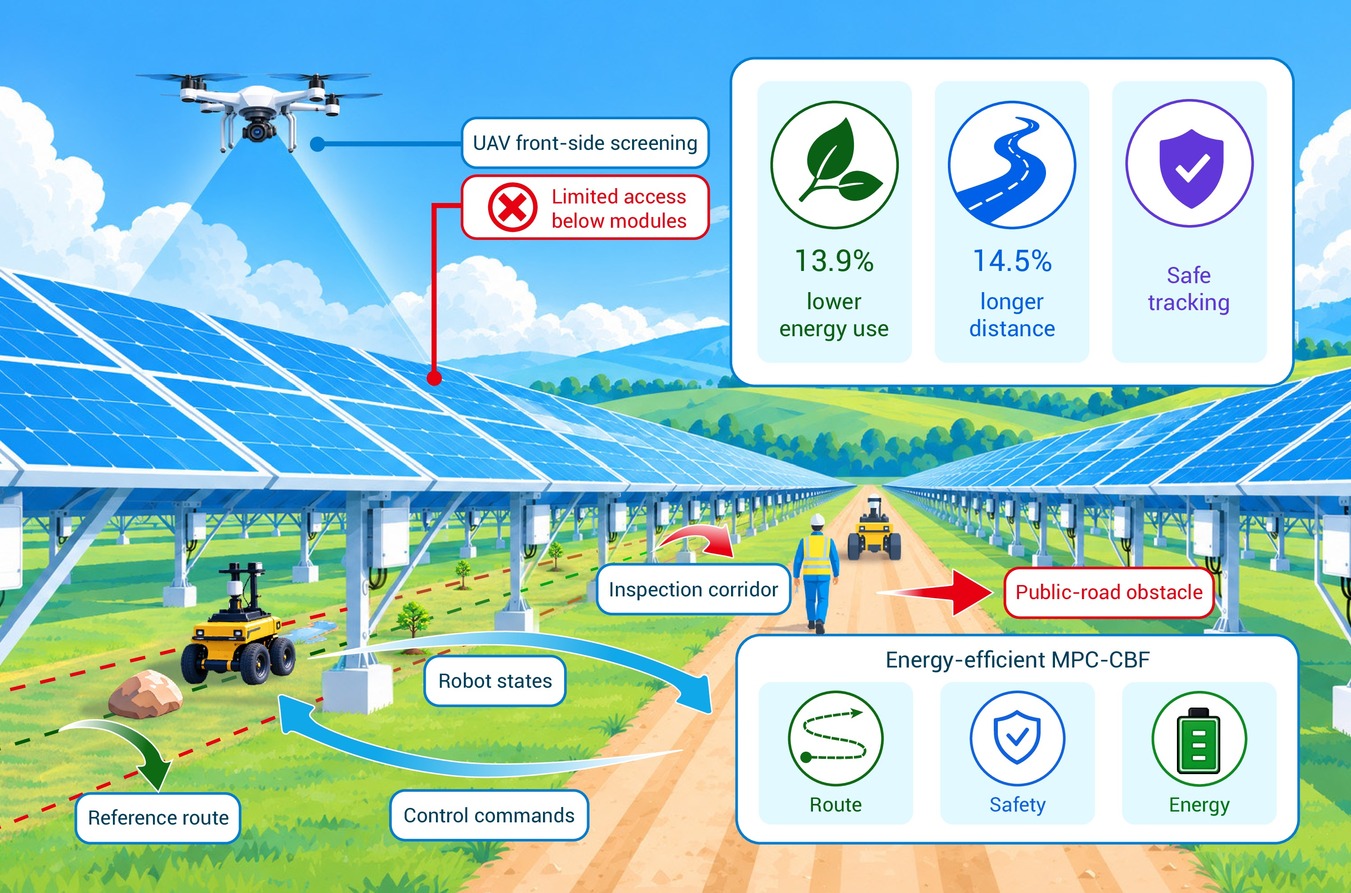
GRAPHICAL ABSTRACT
 DownLoad:
Full size image
-
PUBLIC SUMMARY
-
An energy-efficient model predictive control–control barrier function (MPC-CBF) controller is developed for safe under-panel photovoltaic (PV) inspection.
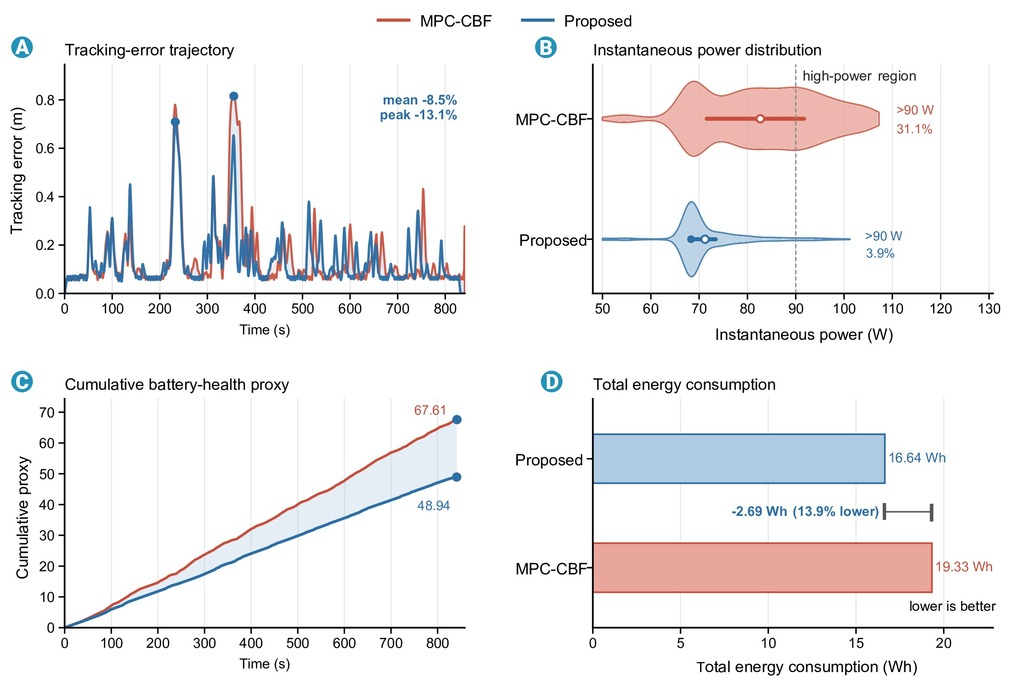
The fixed-task test shows a 13.9% energy reduction over standard MPC-CBF.
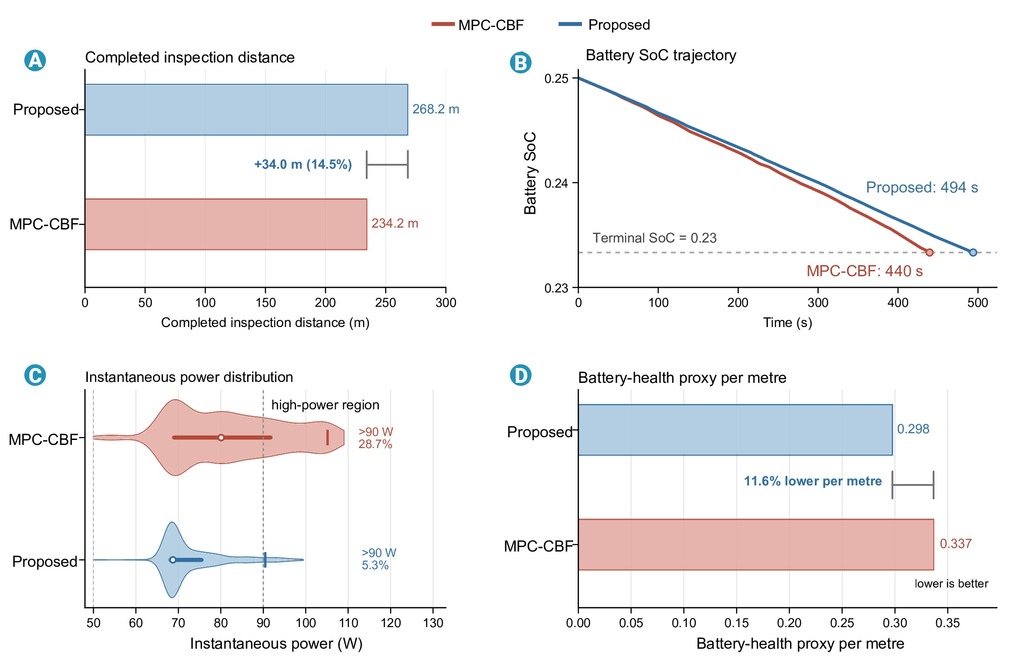
The limited-energy test shows a 14.5% increase in completed inspection distance.
-
-
ABSTRACT
Large-scale ground-mounted photovoltaic (PV) plants are expanding toward ultra-large deployment, making efficient operation and maintenance (O&M) critical for power-generation revenue, equipment reliability, and maintenance-cost reduction. Although unmanned aerial vehicle (UAV) inspection improves large-area inspection efficiency, it remains limited by endurance, under-panel accessibility, and adaptability to complex environments. A low-profile ground robot can access spaces beneath PV modules for close-range inspection, making it an important tool for intelligent PV plant O&M. This paper proposes an energy-efficient automated inspection method for a low-profile ground robot in PV module backsheet and under-panel scenarios by integrating model predictive control (MPC) and control barrier functions (CBFs). CBFs are used to describe corridor-boundary and obstacle-avoidance requirements, while robot energy consumption and the battery-usage proxy are incorporated into the MPC framework to improve inspection energy efficiency. Simulation results show that, compared with standard MPC-CBF, reduces energy consumption by 13.9% in the fixed-task test and increases the inspection distance by 14.5% in the limited-energy test, validating its potential for energy-saving inspection in large PV plants. -

-
REFERENCES
[1] Høiaas I., Grujic K., Imenes A.G., et al. (2022). Inspection and condition monitoring of large-scale photovoltaic power plants: A review of imaging technologies. Renew. Sustain. Energy Rev. 161:112353. DOI:10.1016/j.rser.2022.112353 [2] Zhang H., Chen Y., Jin Y., et al. (2025). Greenhouse-integrated solar photovoltaics for sustainable future energy landscapes. Innov. Energy 2:100124. DOI:10.59717/j.xinn-energy.2025.100124 [3] He T., Chen Y., Zhao Y., et al. (2025). Harnessing the solar photovoltaic potential in global mining areas: Energy locations for the future. The Innovation 6:100987. DOI:10.1016/j.xinn.2025.100987 [4] Shao C., Yang K., Zhang X., et al. (2025). Land constraint makes solar trackers less effective for photovoltaic power generation. Innov. Energy 2:100103. DOI:10.59717/j.xinn-energy.2025.100103 [5] Akram M.W., Li G., Jin Y., et al. (2022). Failures of photovoltaic modules and their detection: A review. Appl. Energy 313:118822. DOI:10.1016/j.apenergy.2022.118822 [6] Tang W., Yang Q., Dai Z., et al. (2024). Module defect detection and diagnosis for intelligent maintenance of solar photovoltaic plants: Techniques, systems and perspectives. Energy 297:131222. DOI:10.1016/j.energy.2024.131222 [7] Polymeropoulos I., Bezyrgiannidis S., Vrochidou E., et al. (2024). Enhancing solar plant efficiency: A review of vision-based monitoring and fault detection techniques. Technologies 12(10):175. DOI:10.3390/technologies12100175 [8] Kuznetsov P., Kotelnikov D., Yuferev L., et al. (2022). Method for the automated inspection of the surfaces of photovoltaic modules. Sustainability 14:11930. DOI:10.3390/su141911930 [9] Michail A., Livera A., Tziolis G., et al. (2024). A comprehensive review of unmanned aerial vehicle-based approaches to support photovoltaic plant diagnosis. Heliyon 10:e23983. DOI:10.1016/j.heliyon.2024.e23983 [10] Buerhop C., van Dyk E.E., Vorster F.J., et al. (2025). Enhancing the cost- and time-effectiveness of field PV module inspection by UV-fluorescence imaging. IEEE J. Photovolt. 15:30−39. DOI:10.1109/JPHOTOV.2024.3492286 [11] Addabbo P., Angrisano A., Bernardi M.L., et al. (2018). UAV system for photovoltaic plant inspection. IEEE Aerosp. Electron. Syst. Mag. 33:58−67. DOI:10.1109/MAES.2018.170145 [12] Li X., Li W., Yang Q., et al. (2020). An unmanned inspection system for multiple defects detection in photovoltaic plants. IEEE J. Photovolt. 10:568−576. DOI:10.1109/JPHOTOV.2019.2955183 [13] de Oliveira A.K.V., Aghaei M., and Rüther R. (2022). Automatic inspection of photovoltaic power plants using aerial infrared thermography: A review. Energies 15:2055. DOI:10.3390/en15062055 [14] Barraz Z., Sebari I., Lamrini N., et al. (2025). Fast and automatic solar module geo-labeling for optimized large-scale photovoltaic systems inspection from UAV thermal imagery using deep learning segmentation. Cleaner Eng. Technol. 28:101048. DOI:10.1016/j.clet.2025.101048 [15] Mahdavipour Z. (2024). Defect inspection of photovoltaic solar modules using aerial electroluminescence (EL): A review. Sol. Energy Mater. Sol. Cells 278:113210. DOI:10.1016/j.solmat.2024.113210 [16] Solend T.A., Rødningsby A., and Moen J. (2025). Impacts of infrared thermographic image blurring on UAV inspection efficiency of solar power plants. Sol. Energy 299:113673. DOI:10.1016/j.solener.2025.113673 [17] Figgis B., Azid S.I., and Parlevliet D.A. (2025). Review of unmanned ground vehicles for PV plant inspection. Sol. Energy 291:113404. DOI:10.1016/j.solener.2025.113404 [18] Wang F., Gao Y., Chen Z., et al. (2023). A path planning algorithm of inspection robots for solar power plants based on improved RRT*. Electron. 12:4455. DOI:10.3390/electronics12214455 [19] Wang Y. (2017). Design of inspection robot system based on photovoltaic effect. Adv. Mater. Mach. Elect. Eng. 114:259−262. DOI:10.2991/ammee-17.2017.51 [20] Hu H., Chen Q., Xie Y., et al. (2025). A novel robotic platform for photovoltaic panel inspection with progressive structural configuration and constant speed regulation. EEICE :1535−1538. DOI:10.1109/EEICE65049.2025.11034170 [21] De Benedetti M.M., Bascetta L., Falsone A., et al. (2024). Automated photovoltaic power plant inspection via unmanned vehicles. IEEE Trans. Control Syst. Technol. 32:399−412. DOI:10.1109/TCST.2023.3316093 [22] Amorim J.S.J.C., Neto A.F.S., Chaves R.S., et al. (2025). Collaborative inspection of solar panel farms using YOLOv5-based computer vision and UGV-UAV integration. J. Intell. Robot. Syst. 111:66. DOI:10.1007/s10846-025-02265-w [23] Velasco-Sánchez E., Recalde L.F., Guevara B.S., et al. (2024). Visual servoing NMPC applied to UAVs for photovoltaic array inspection. IEEE Robot. Autom. Lett. 9:2766−2773. DOI:10.1109/LRA.2024.3360876 [24] Xing J., Cioffi G., Hidalgo-Carrió J., et al. (2023). Autonomous power line inspection with drones via perception-aware MPC. IROS :1086−1093. DOI:10.1109/IROS55552.2023.10341871 [25] Gao L., Gao Y., He M., et al. (2025). Safety-critical model predictive control for trajectory tracking and obstacle avoidance of wheeled mobile robot formations. Trans. Inst. Meas. Control 48:1−14. DOI:10.1177/01423312251331274 [26] Jiang C. and Guo Y. (2024). Incorporating control barrier functions in distributed model predictive control for multirobot coordinated control. IEEE Trans. Control Netw. Syst. 11:547−557. DOI:10.1109/TCNS.2023.3290430 [27] Zeng J., Zhang B. and Sreenath K. (2021). Safety-critical model predictive control with discrete-time control barrier function. ACC :3882−3889. DOI:10.23919/ACC50511.2021.9483029 [28] Kim Y., He C.R. and Singh T. (2024). Control barrier function based energy optimal obstacles avoidance for point-to-point maneuvers. IFAC-PapersOnLine 58:857−862. DOI:10.1016/j.ifacol.2025.01.103 [29] Zhu L., Tao F., Fu Z., et al. (2025). Safety-involved co-optimization of speed trajectory and energy management for fuel cell-battery electric vehicle in car-following scenarios. Complex Intell. Syst. 11:89. DOI:10.1007/s40747-024-01698-4 [30] Nie Z., Jia Y., Wang W., et al. (2022). Eco-co-optimization strategy for connected and automated fuel cell hybrid vehicles in dynamic urban traffic settings. Energy Convers. Manag. 263:115690. DOI:10.1016/j.enconman.2022.115690 [31] Gao L., Gao Y.-F., Wang X.-F., et al. (2026). Space-constrained multi-robot formation control via an enhanced discrete-time control Lyapunov and barrier function approach. IEEE Trans. Autom. Sci. Eng. 23:6190−6203. DOI:10.1109/TASE.2026.3669894 [32] Wei L., Liao Y., Liu J., et al. (2025). Safety-critical model predictive trajectory tracking control for transformer inspection robots based on control barrier functions. PowerCon :1−6. DOI:10.1109/POWERCON66300.2025.11294480 -
ABOUT THIS ARTICLE
Cite this article:
Gao L., Le S., Zhao X., et al. (2026). Energy-efficient robotic inspection in under-panel spaces of photovoltaic plants. The Innovation Energy 3:100190. https://doi.org/10.59717/j.xinn-energy.2026.100190
Welcome!
To request copyright permission to republish or share portions of our works, please visit Copyright Clearance Center's (CCC) Marketplace website at marketplace.copyright.com.
Export File
Citation
Gao L., Le S., Zhao X., et al. (2026). Energy-efficient robotic inspection in under-panel spaces of photovoltaic plants. The Innovation Energy 3:100190. https://doi.org/10.59717/j.xinn-energy.2026.100190

Format
Content
-
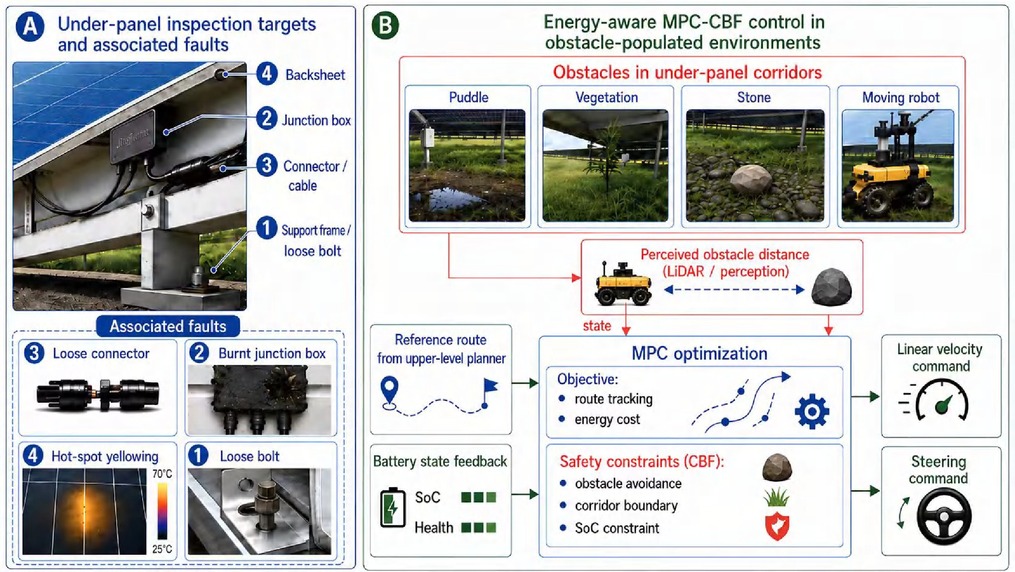
Figure 1.
Under-panel inspection targets, associated faults, and energy-aware predictive safety control framework.
-
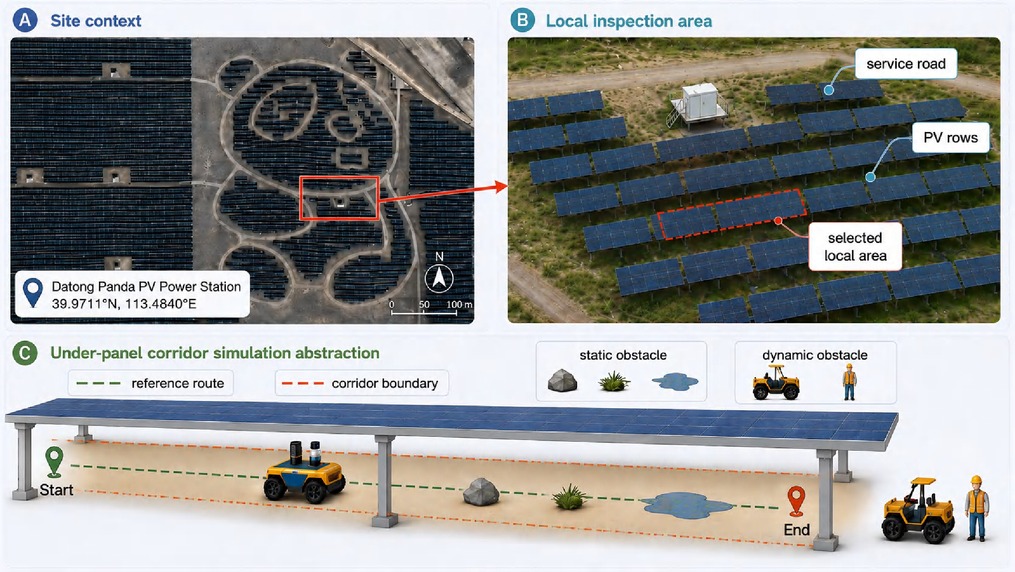
Figure 2.
Simulation scenario for under-panel PV inspection. (A) Satellite view of the selected local area in the Datong Panda PV Power Station. (B) Enlarged local inspection area used as the prototype. (C) Corridor-level simulation abstraction with the reference route, corridor boundary, static obstacles, and dynamic obstacle.
-
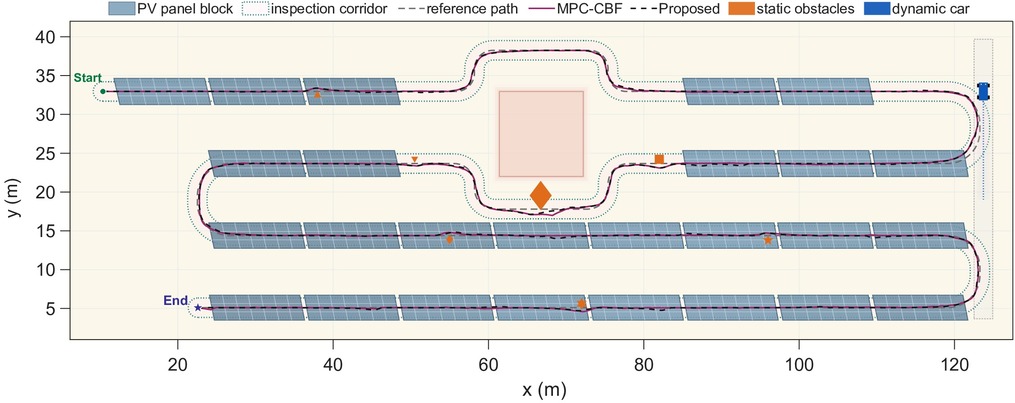
Figure 3.
Trajectory comparison under the fixed inspection task.
-
Figure 4.
Simulation results under the fixed inspection task.
-
Figure 5.
Simulation results under the limited energy budget.
